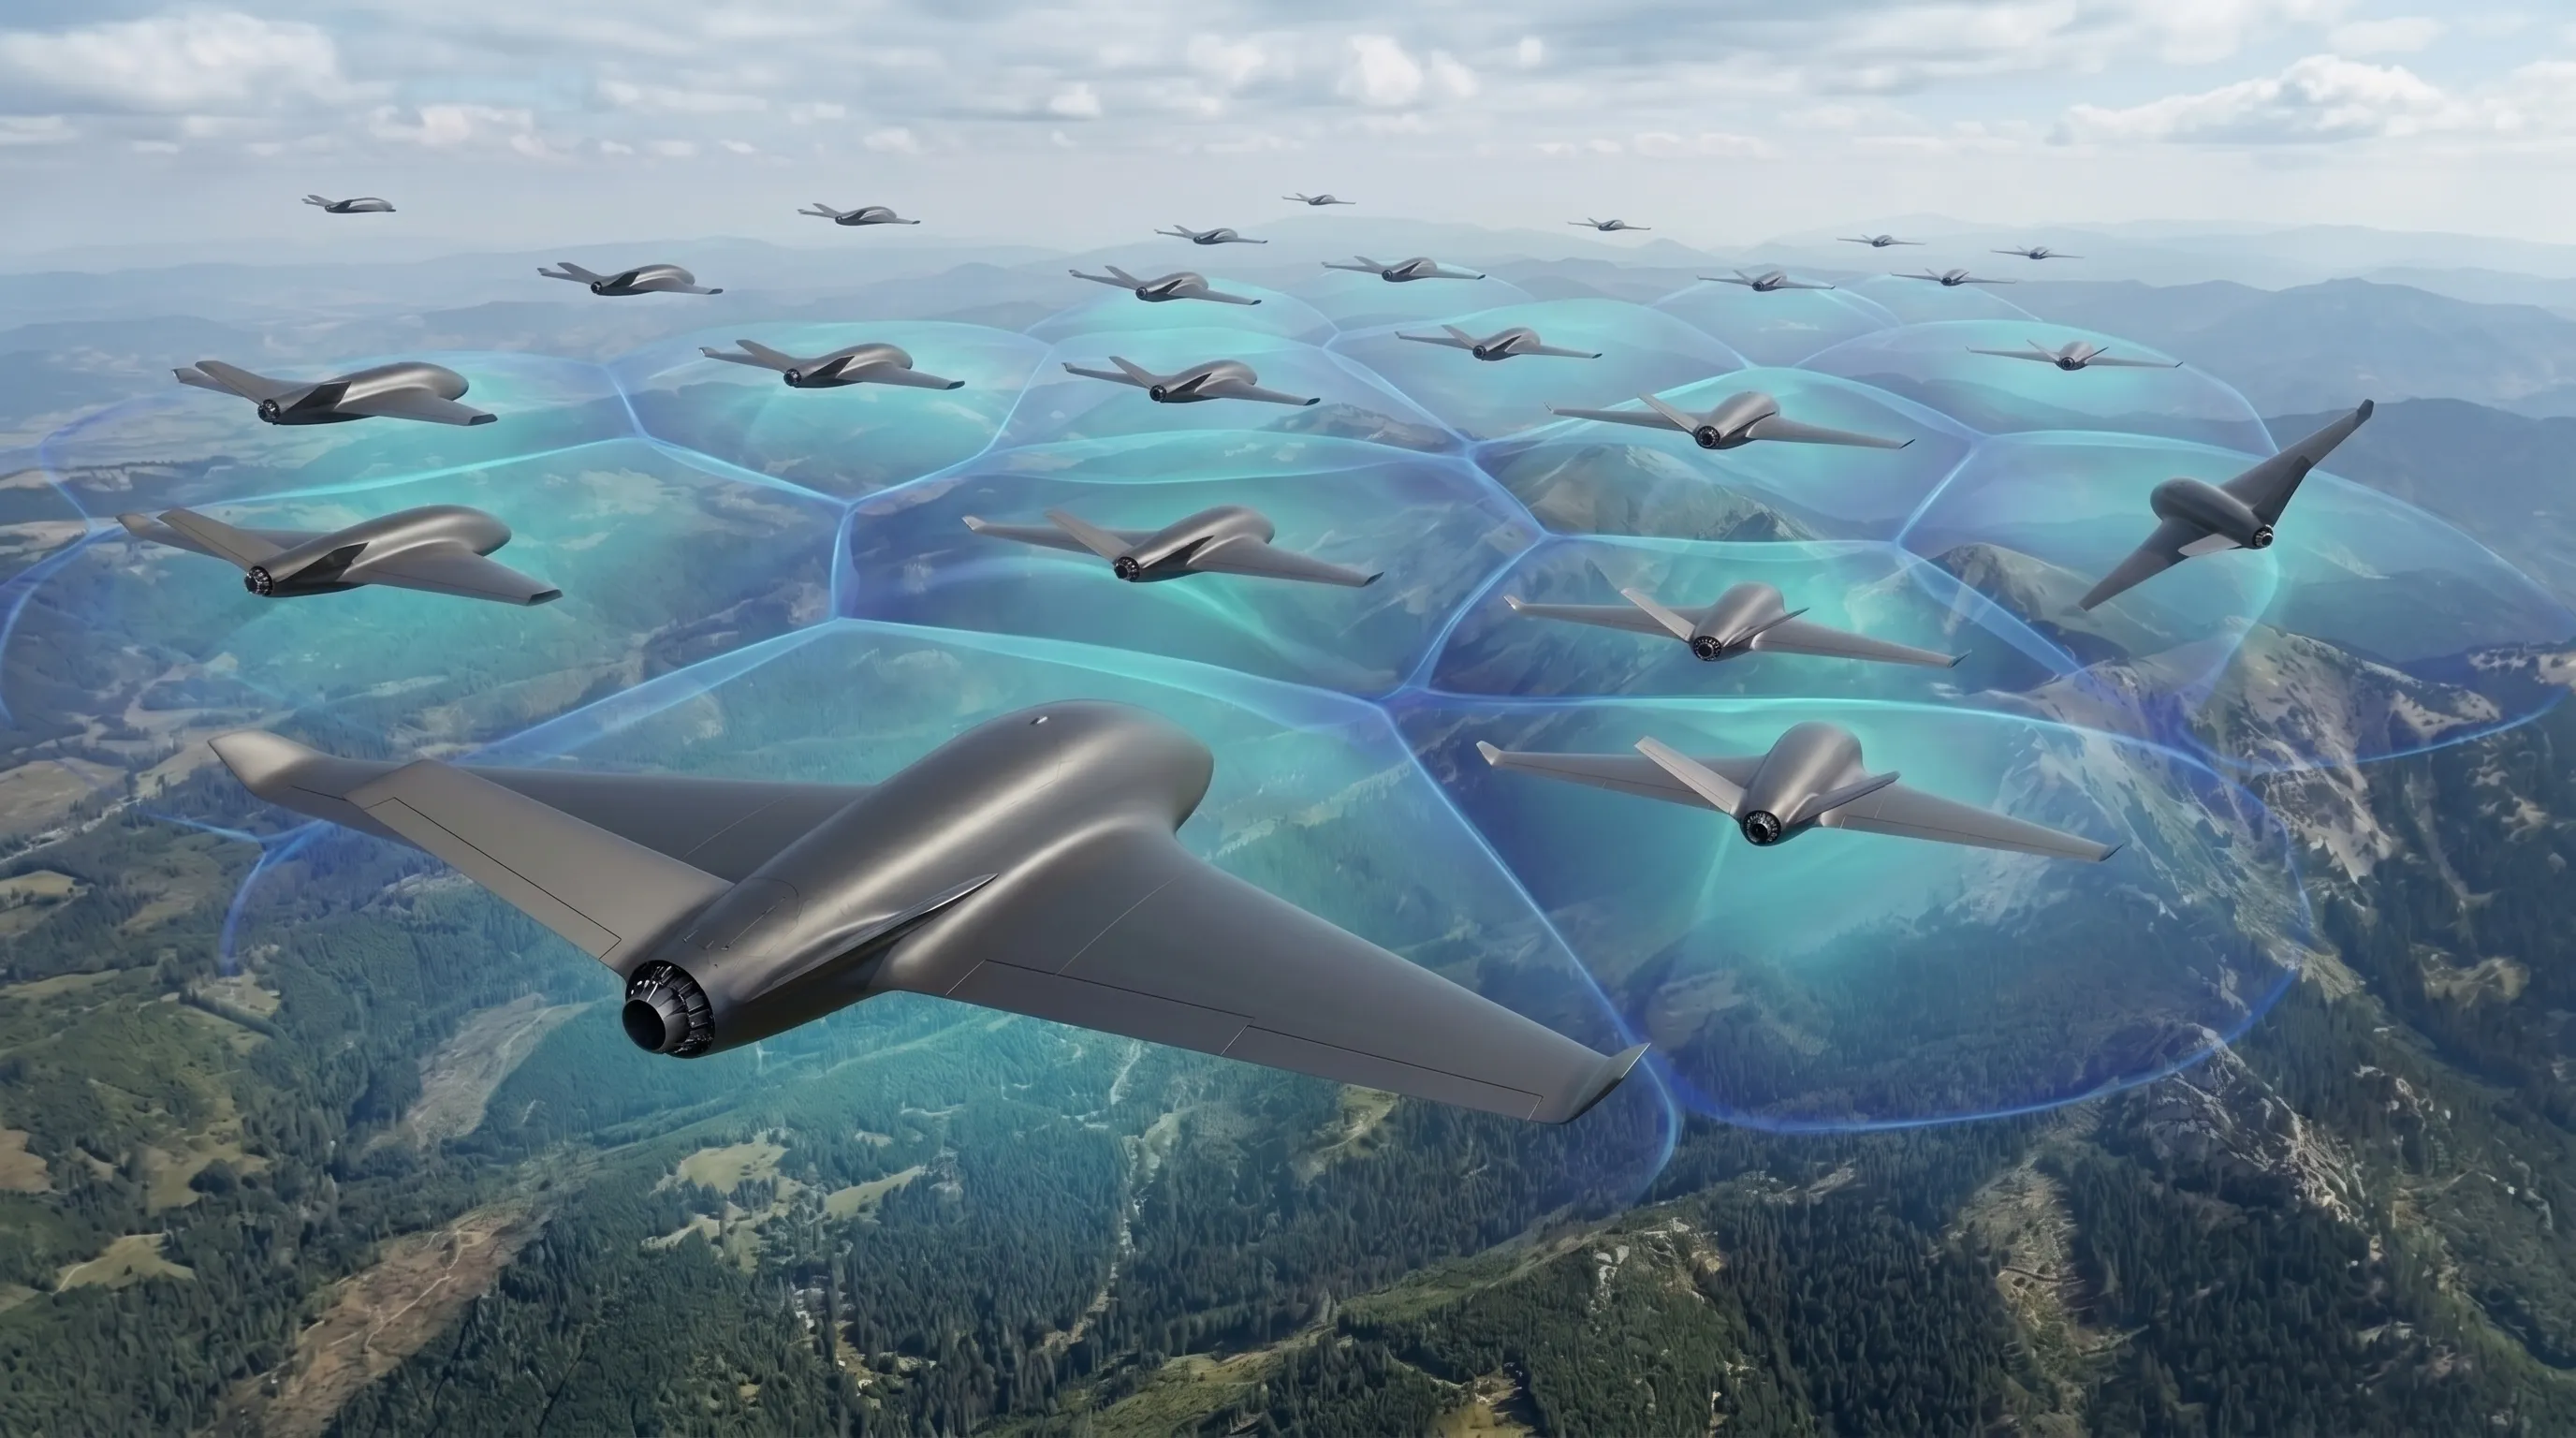
QSI-SS — Quantum Swarm Intelligence with State Superposition, “quantum swarm intelligence with superposition of states.” AERIS is developing this technology to form interconnected solutions in autonomous robotic systems. In NEXUS, it is part of the learning core of the collective mind: neural representations of the situation, registers of alternatives and interactions between participants form a single process of choosing behavior.
The purpose of QSI-SS is to take into account the dependencies within the collective solution. The action of one robot changes the conditions in which the others operate: the availability of observations, the distribution of tasks, the consumption of resources and the subsequent capabilities of the group. These connections must participate in the evaluation of options before each device begins execution.
What does QSI-SS mean?
Quantum denotes the mathematical apparatus used: complex amplitudes, phase transformations, superposition and interference. Swarm Intelligence — swarm intelligence, in which the states of participants influence collective choice. State Superposition — joint representation of several possible states or behavior options in one register.
In the onboard implementation of NEXUS, these operations are performed numerically on classical computers. In this sense, QSI-SS belongs to the direction of quantum-inspired algorithms. The term describes a computational representation device; exchange between devices is carried out via conventional communication channels.
Superposition as a representation of alternatives
The cognitive module transforms available information into a neural representation and a complex register. Its components correspond to the alternatives under consideration. At this level, the system stores a distribution of options that changes under the influence of context, neighbor states, and trained transformations.
The general mathematical notation for such a register is:
ψ = ∑a αa |a⟩, ∑a |αa|² = 1
Here, a denotes an alternative, and α — its complex amplitude. The squared magnitude of the amplitude specifies the component of the normalized distribution. The phase preserves an additional relationship between the contributions, which manifests itself during their interaction. This distribution is part of the choice model; the likelihood of successfully performing a physical action requires a separate assessment of conditions and consequences.
Superposition allows the structure of alternatives to be transformed before the final choice. An observation that changes the meaning of a situation can redistribute the contribution of several options simultaneously. The size of the register and the set of actions under consideration are determined by the computational formulation of the problem.
Why is phase important?
When complex contributions are combined, the result depends on their relative phase. This can be seen from the general formula for the interference of two amplitudes:
|α + β|² = |α|² + |β|² + 2 Re(αβ*)
The last term describes the interaction of contributions; sign * means complex conjugation. With the same amplitude magnitudes, a change in the relative phase can strengthen or weaken the final component. Therefore, numerical weights of alternatives alone are not enough to describe such a transformation.
In QSI-SS, phase relations are related to participants' learned representations. The attention mechanism determines the significance of available states, and phase interaction is involved in the formation of the resulting distribution. Learning tunes these transformations based on feedback from system behavior.
The interference here has a specific computational role: it changes the distribution of the options under consideration. The usefulness of this change is assessed by the outcome of the task and the quality of subsequent choices.
Interdependence of participants' decisions
Combinations of actions are essential for collective behavior. If one robot refines an observation, the usefulness of the other's action depends on what information the first can obtain and when it becomes available. Pairwise QSI-SS factors allow such dependencies to be included in the transformation of the two participants' options.
In the NEXUS core, a joint pairwise representation is used to obtain the distribution relevant to the selection of a particular node. It is combined with the result of mixing the available registers. Thus, the local solution retains dependence on the state of other participants, and the nature of this dependence is specified by the trainable parameters.
Interaction is limited to the current graph of available connections. The node receives its own state and the resolved context of its neighbors. Changing the composition of the group changes this context; an absent or incompatible participant is excluded from the actual calculation. This makes an explicit connection between the availability of information and the basis for the decision.
Suppression of options and distribution of participation
Additional mechanism anti-state forms a trained complex contribution, which participates in the suppression of certain components of the resulting register. Its action depends on the current view of the situation. This mechanism expands the set of transformations that the model has when forming preferences.
Model preference and physical feasibility have different meanings. Acceptable actions are determined by individual vehicle and mission constraints. Low option weight means evaluation within the model; execution prohibition is specified by checking conditions that cannot be violated.
Participation assessment, ownership, describes the relative contribution of the available nodes for the considered variants of the problem. It enters into learned choice and links the collective context with the distribution of functions. At the same time, the assignment of the role is also based on the state of the mission and the real capabilities of the performer.
A unified trainable computational process
In NEXUS, neural encoding and QSI-SS are combined in a single trainable core. The presentation of observations influences case, case influences interactions with neighbors, and the resulting context influences behavioral choices. Performance feedback allows you to change the parameters of these related steps.
| Mechanism | What does it represent? | Contribution to the solution |
|---|
| Neural representation | Context of observation, task and available opportunities | Determines which situational differences influence choice |
|---|
| Complex register | Amplitudes and phases of the alternatives under consideration | Maintains the structure of options before selecting an action |
|---|
| Inter-node communication | States of available participants and pairwise dependencies | Connects evaluation of one's own actions with the behavior of others |
|---|
| Cooperative learning | Confirmed execution and result of the overall mission | Configures presentation, interactions, and selection in one loop |
|---|
Cooperative learning evaluates the contribution of behavior to the overall mission, taking into account time and constraints. The material for updating is the causal sequence: available context, proposed action, confirmed execution, and measured outcome. It allows parameter changes to be associated with the behavior that was actually executed.
Training the model and its use on board are separated. The prepared parameters are transferred to a compact computational representation for execution. The updated model undergoes a separate assessment before approval; data provenance and representation compatibility are preserved when exchanged between participants.
Role of QSI-SS in NEXUS and interaction with F³
AERIS NEXUS integrates perception, memory, prediction, task distribution and learning into a robotic collective intelligence. QSI-SS is responsible for the learnable representation of alternatives and the interaction of states involved in behavioral choice. Collective memory and distributed forecasting provide context for this process and estimates of possible consequences.
AERIS F³ AI pilot connects the choice of action with the dynamics and resources of a particular apparatus. The collective level proposal must be consistent with available management, current status, and mission continuation conditions. Stabilization and direct execution are stored in the local onboard loop.
For example, when surveying an area, two devices may receive different information about one area. This information changes the collective context and assessments of possible continuations. The interaction of states is involved in the choice: which apparatus clarifies the observation, which continues the examination, and how their actions relate to the general task. This example illustrates the purpose of the mechanisms, and the specific outcome is determined by the models, conditions and available resources.
Engineering value of the approach
QSI-SS combines three levels: presentation of multiple alternatives, modeling of their interactions between participants, and learning from the outcome of collective behavior. This allows us to explore how the structure of the collective state affects the decision and tune it together with the neural model.
The quality of this approach is assessed by the mission outcome, solution time, resource consumption, and stability of behavior when observations and connections change. To highlight the contribution of phase and pair mechanisms, comparisons under identical scenarios and comparable computational budgets are essential.
AERIS is developing QSI-SS as part of its robotic systems. The main direction of work is collective intelligence, in which participants jointly form a space of possible actions and use the result of interaction to complete a common task.