BWB Laboratory
We research emerging architectures, materials and technologies for autonomous aircraft systems.

Artificial intelligence
Onboard logic, computer vision and mission planning for unmanned aircraft.
Support
Navigation and sensing
GNSS-denied navigation, multimodal sensor integration and real-time data processing.
Modular architecture
Flexible, modular hardware and software systems that can be adapted to different tasks and platforms.
Composite materials
Composite 3D printing and integrated structures for lightweight, strong UAV airframes.
AERIS APT-1: Airflow Tomography
APT-1 reconstructs the aerodynamic state of a UAV from distributed pressure measurements and onboard system data.
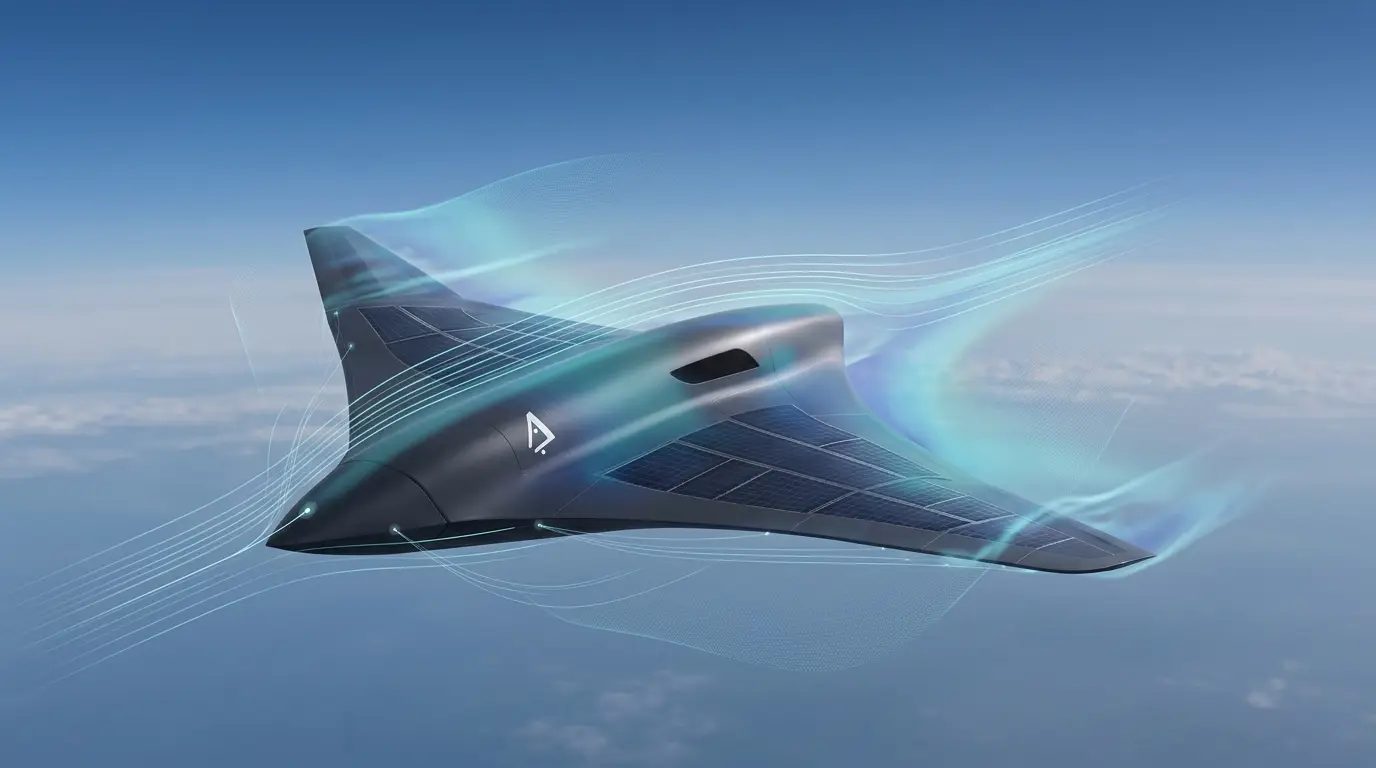
AERIS ARW-1: Aerodynamic Wing Reflex
ARW-1 investigates local wing responses to gusts and pressure changes without waiting for commands from the central control loop.
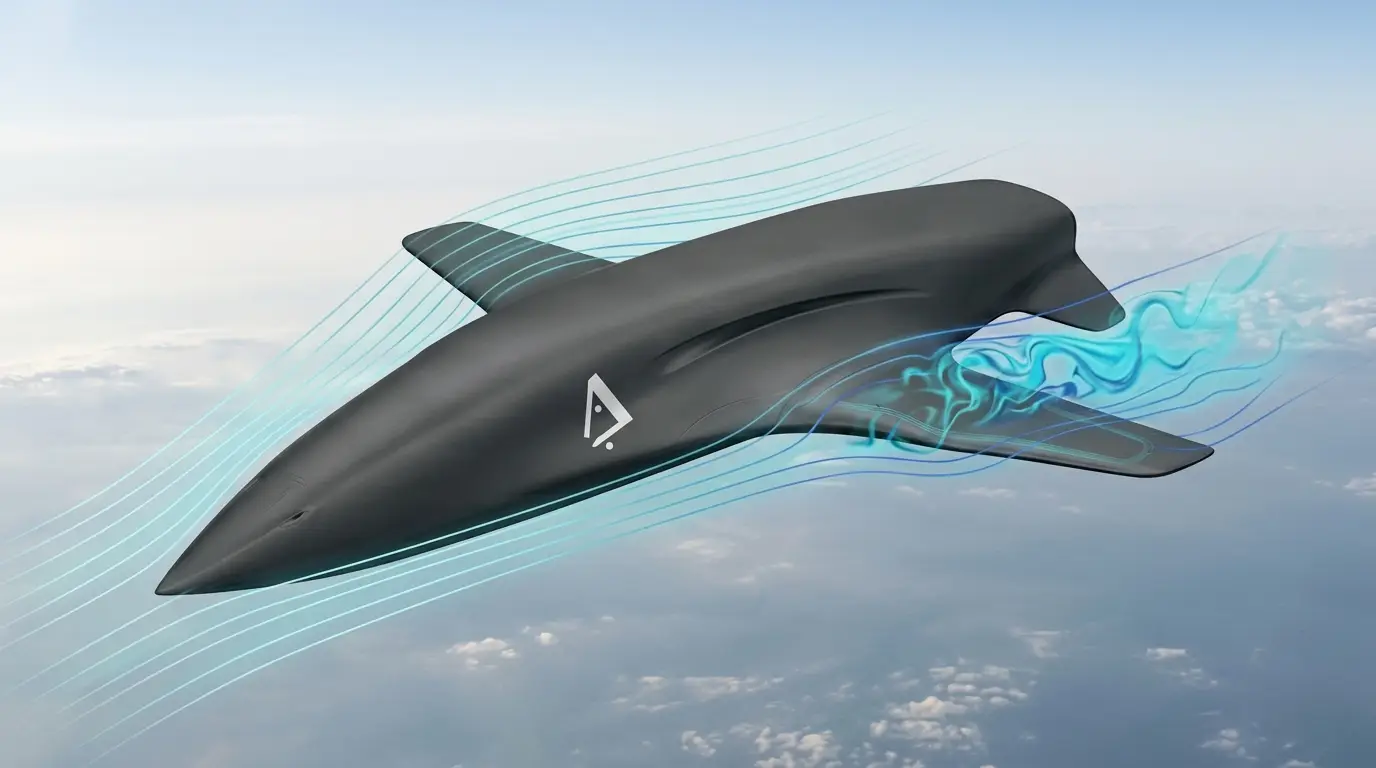
AERIS VectorFlow: Integrated Thrust Vectoring
VectorFlow explores thrust-direction control within the UAV structure to improve control authority without large external mechanisms.
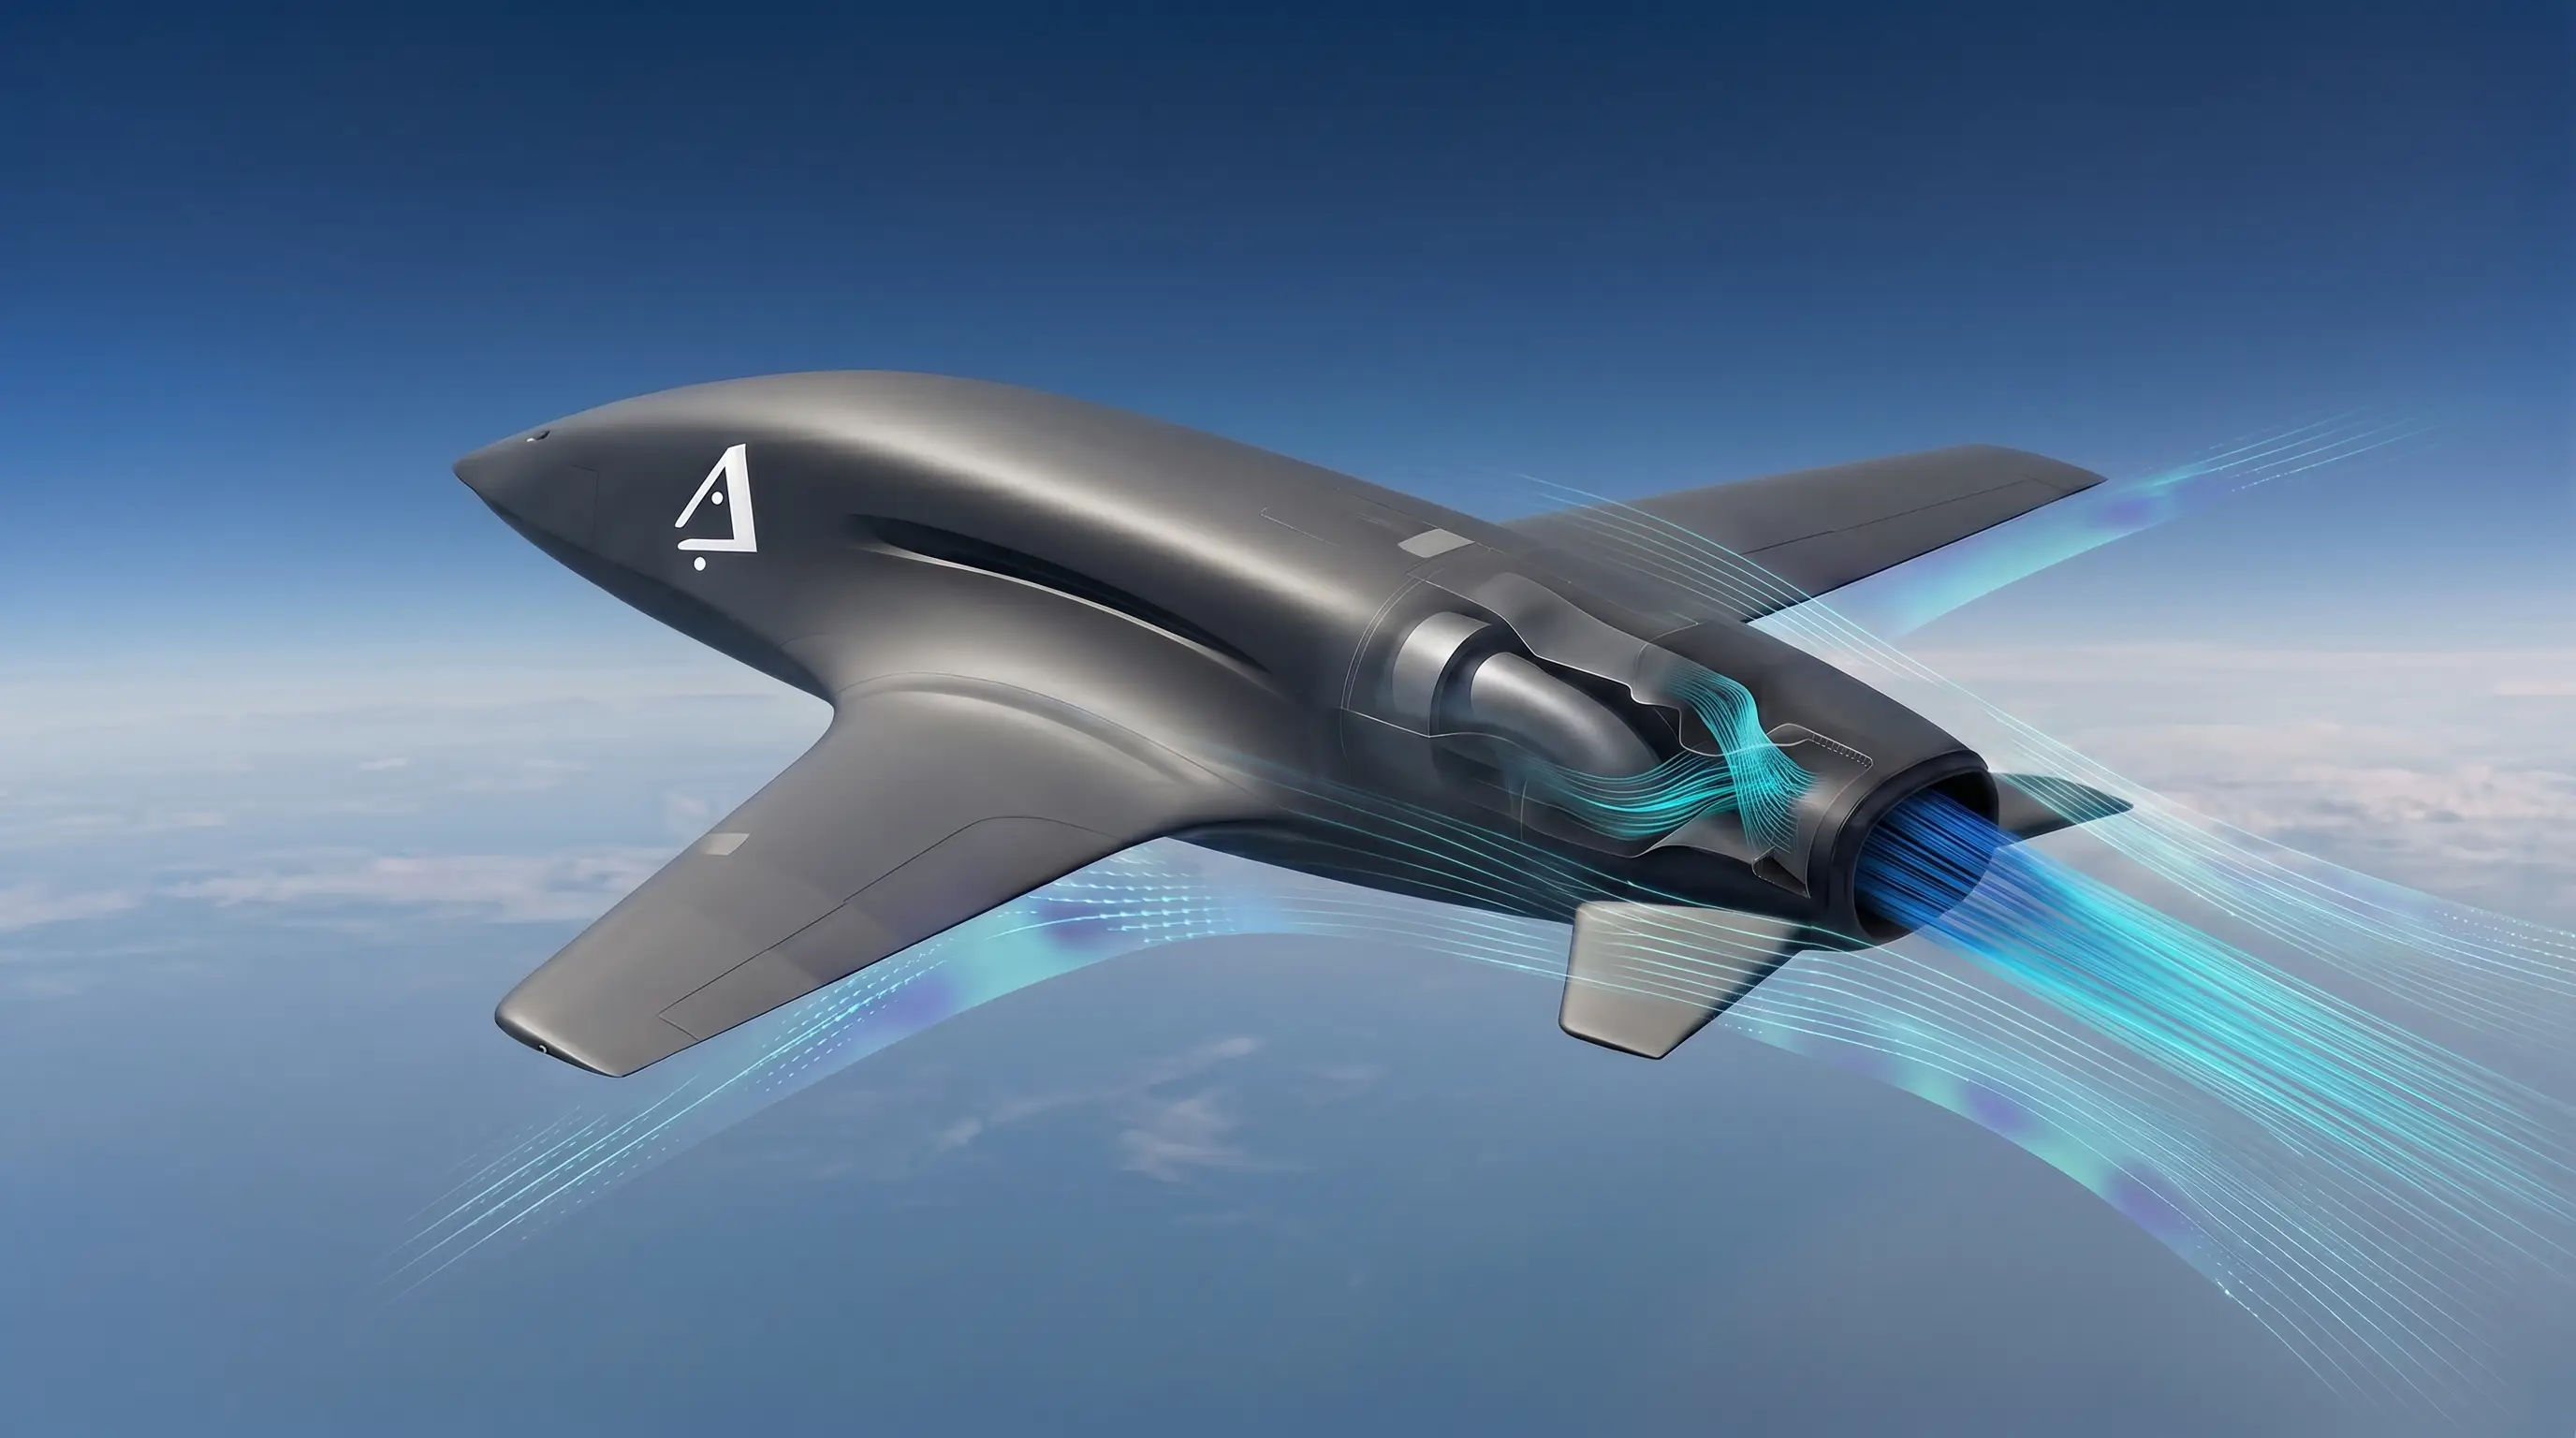
AERIS AEC-1 / CloudSkin: A Distributed Electrostatic Surface
CloudSkin explores the UAV surface as a distributed system for measuring, managing and collecting electrical charge through interaction with the atmosphere.
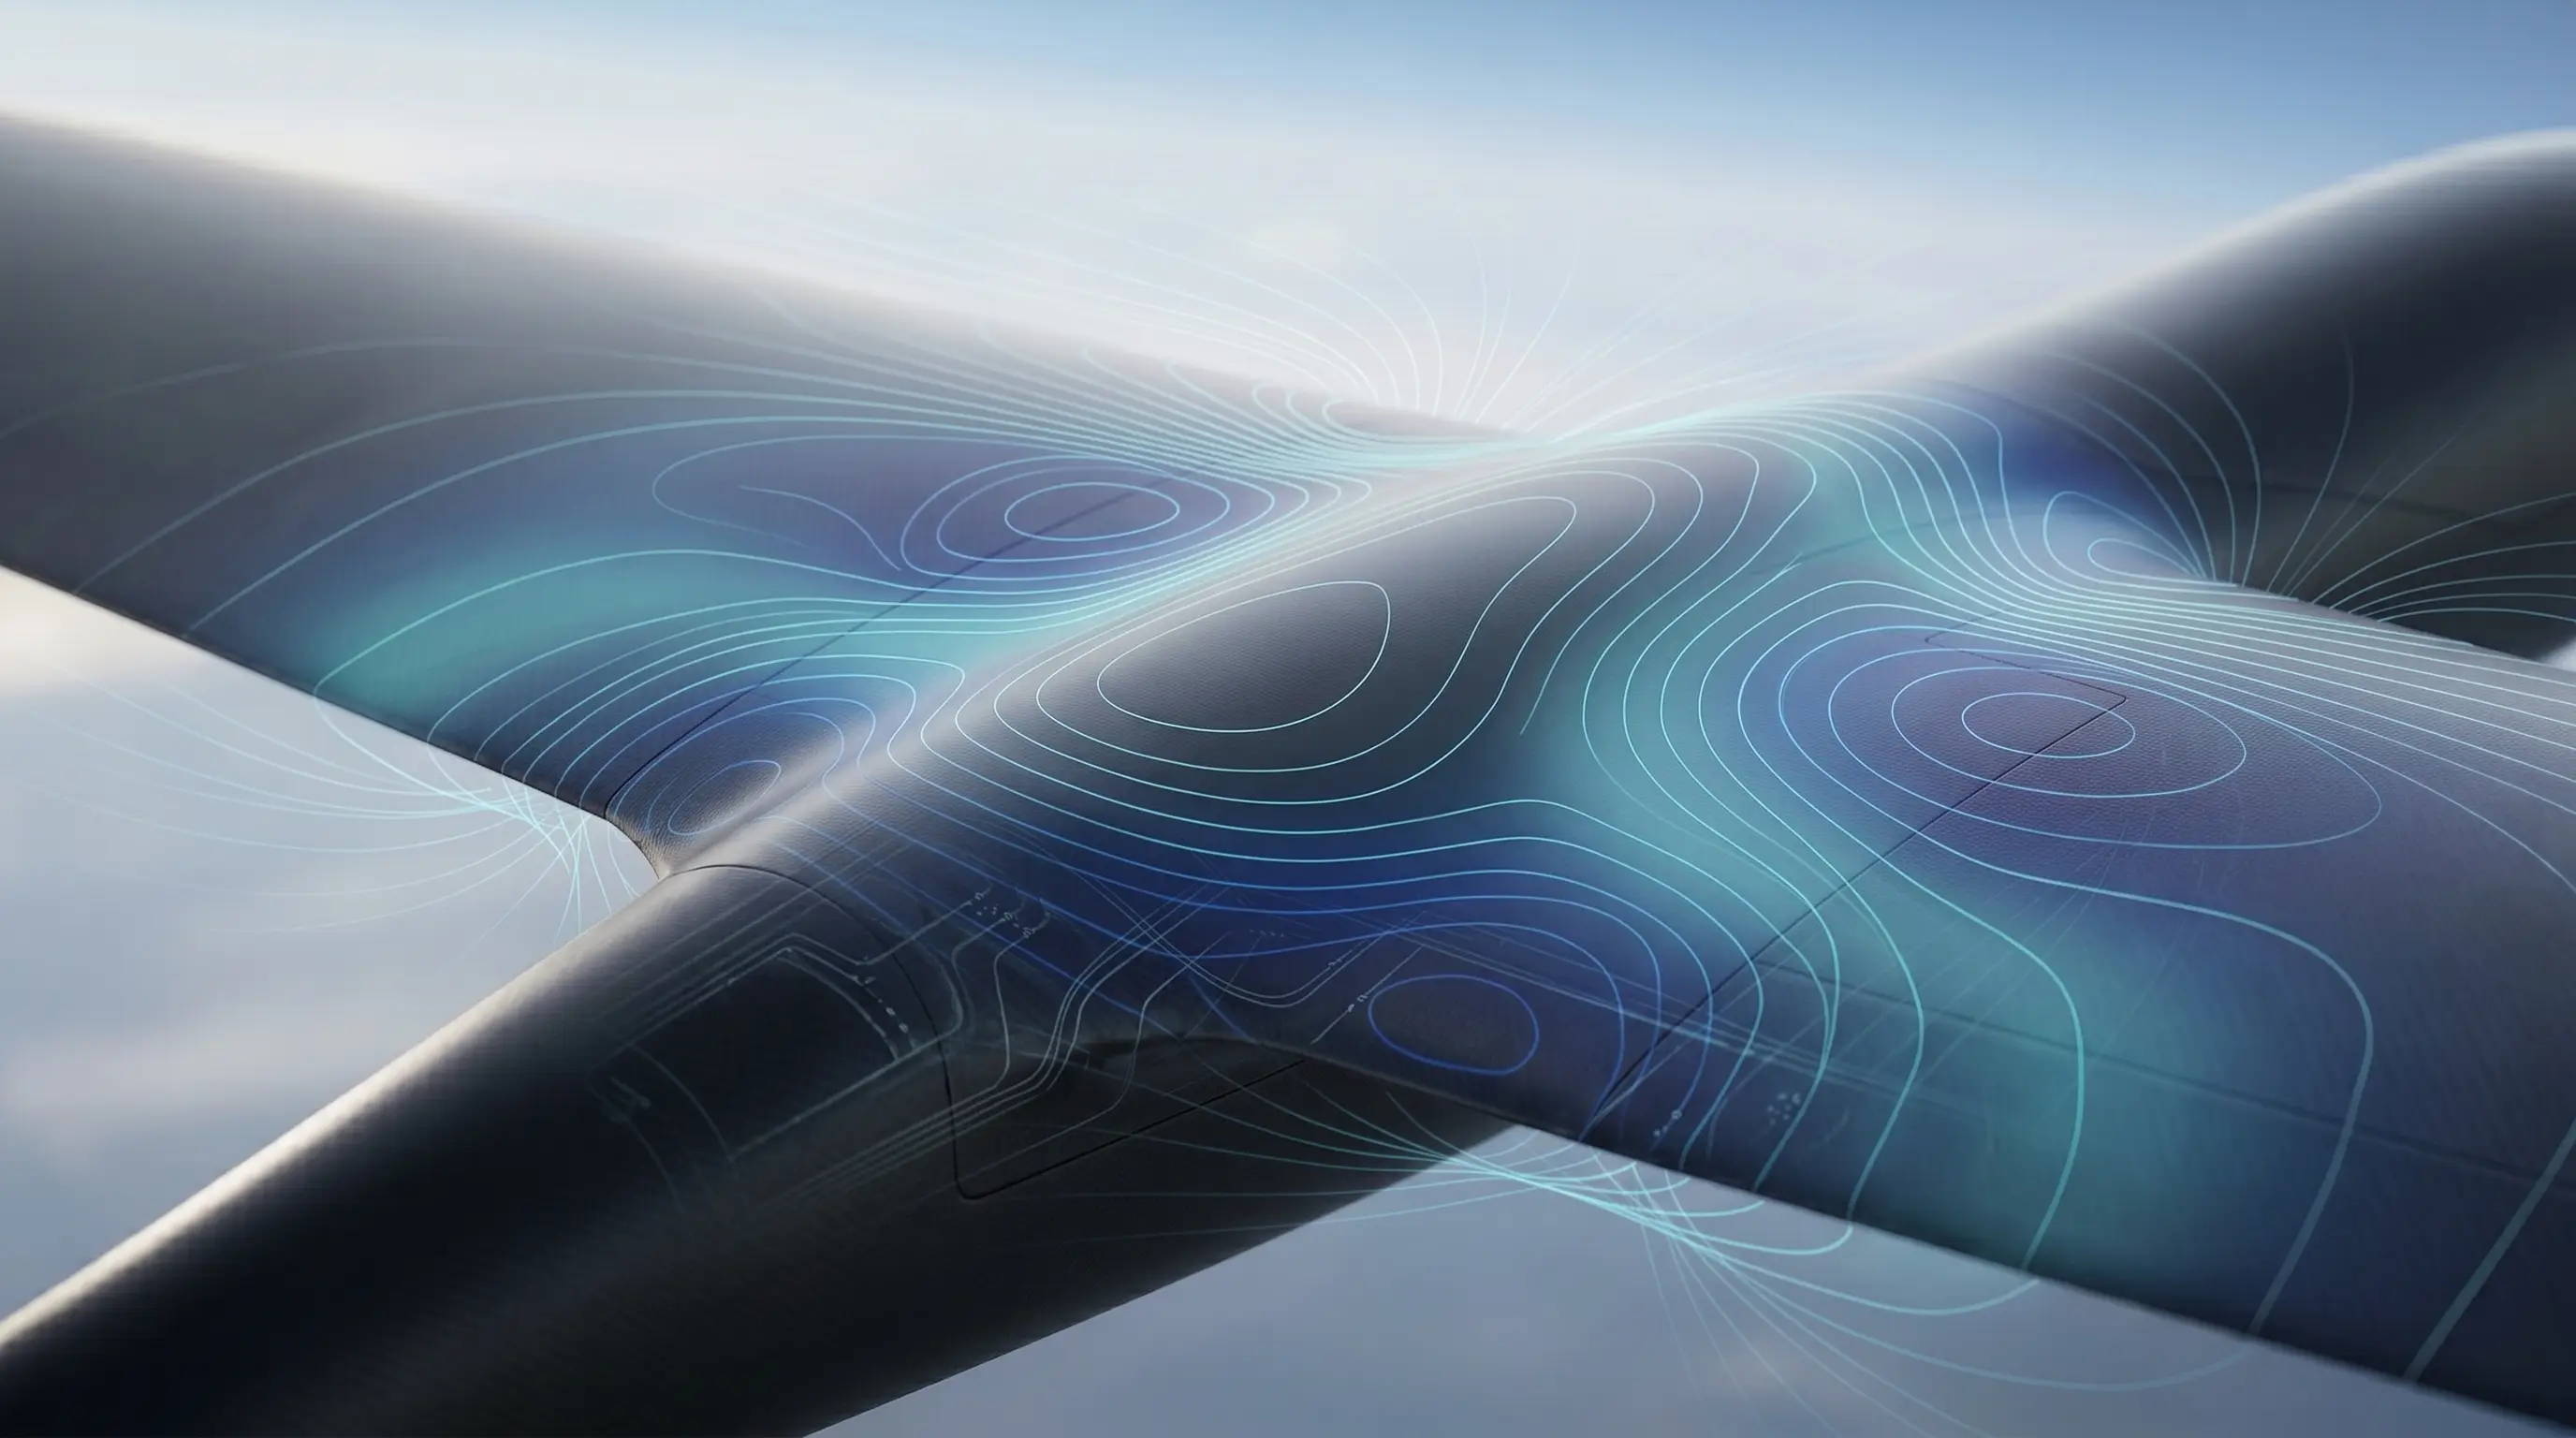
AERIS W-State Topology: Distributed Swarm Coordination
W-State Topology explores distributed coordination of large groups of autonomous vehicles without making the entire system dependent on a single control node.
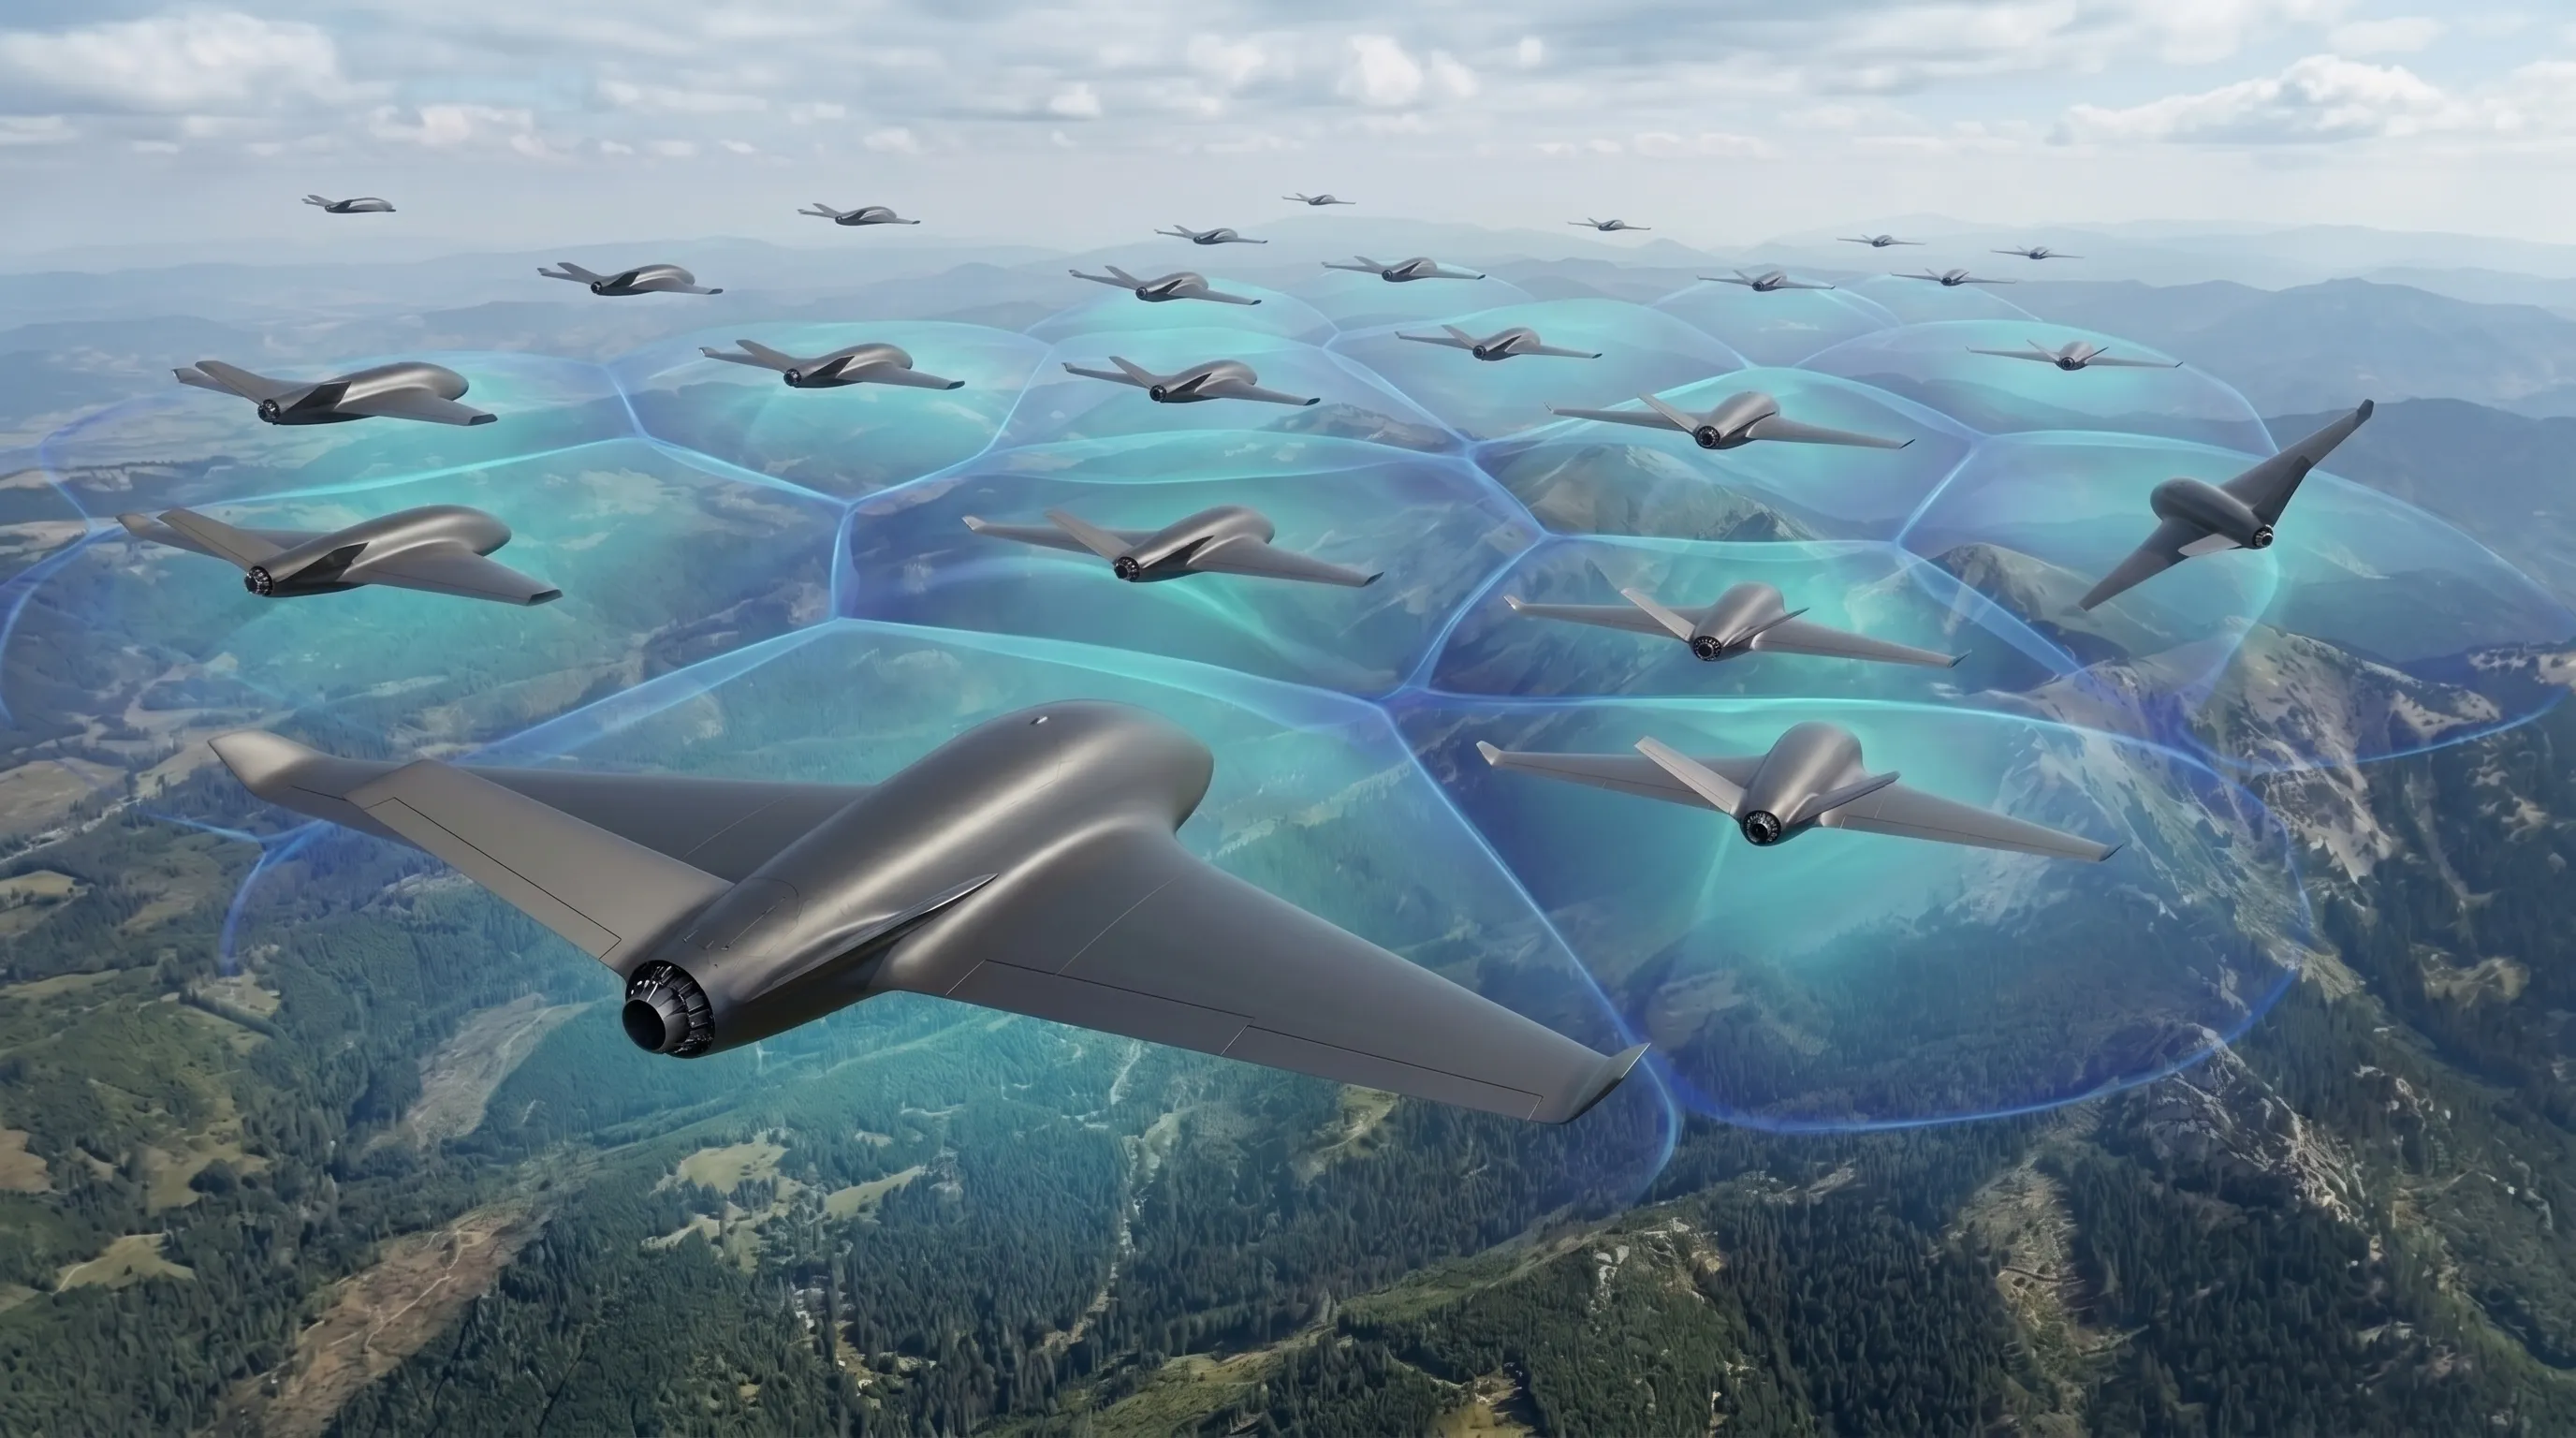
AERIS GNSS-Denied Navigation
The system estimates aircraft motion and position from visual and inertial data when GNSS is absent or unavailable.
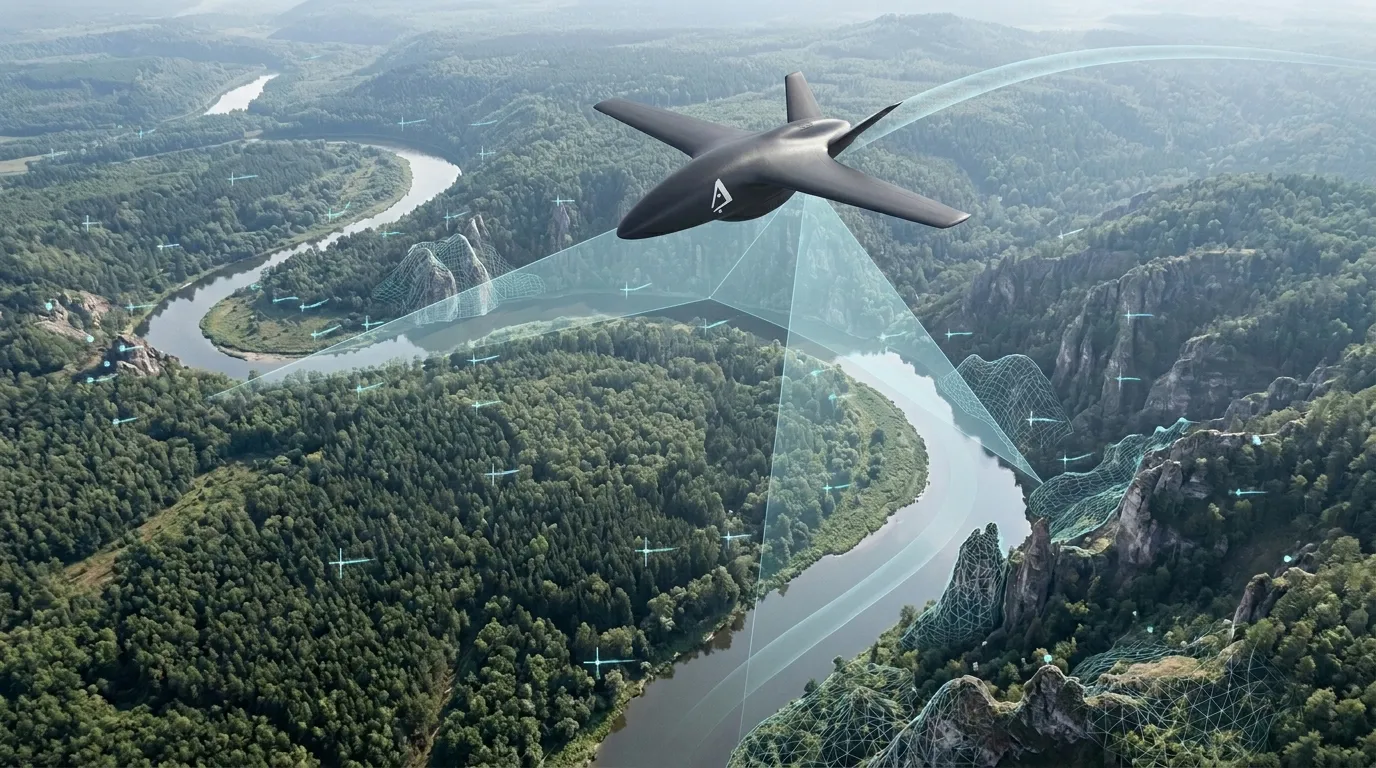
AERIS Mission OS: Autonomous Mission Management
Mission OS combines environmental perception, planning and task execution within an architecture for autonomous mission management.
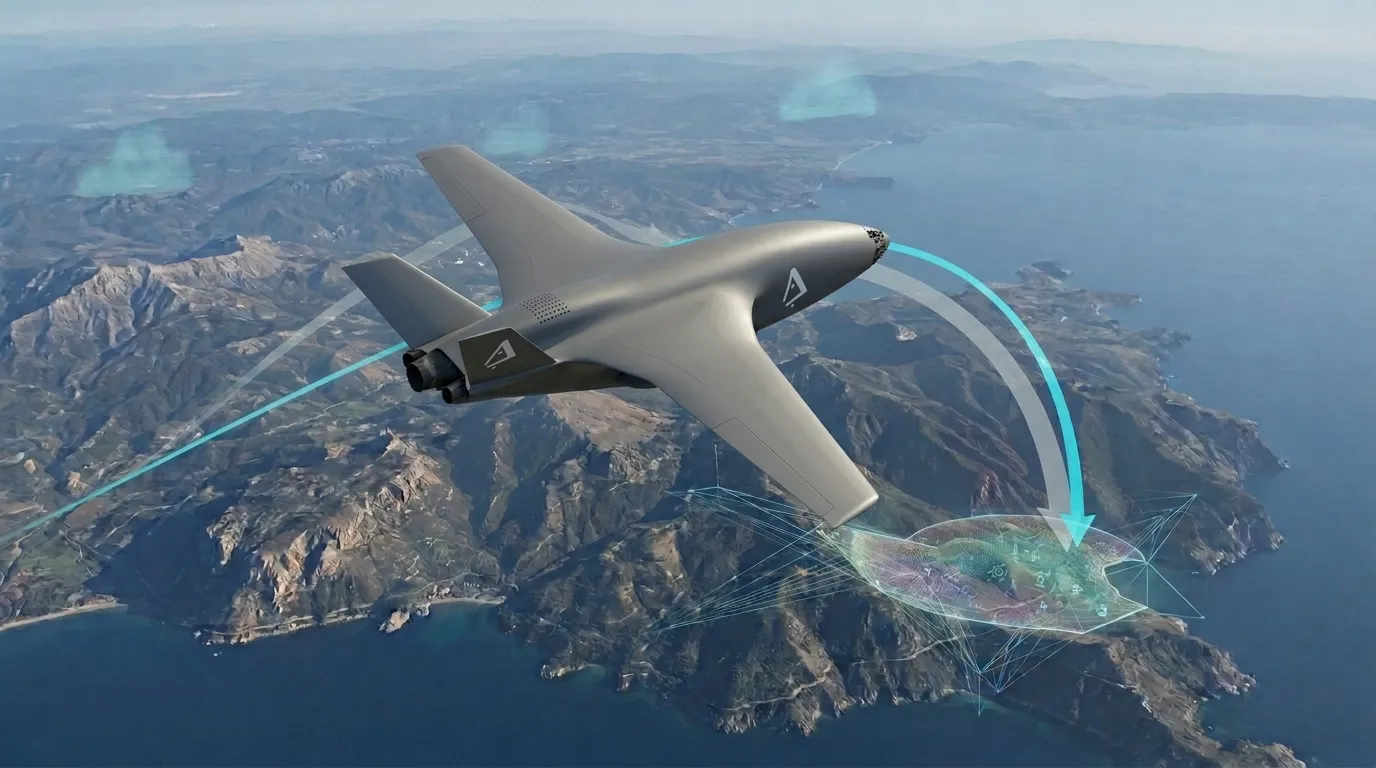
AERIS QSI-SS: Swarm Intelligence with State Superposition
A learned swarm-intelligence mechanism combining complex-valued registers of alternatives, phase interactions and interdependent action selection within NEXUS collective intelligence.